



PhD candidate in Vehicle Engineering at Beijing Institute of Technology (expected June 2027); research in Computer Science and Technology focused on robotic world models and generative policies
Email · LinkedIn · Repositories
I work on robotic world models and generative action policies, video pretraining and post-training, vision-language-action (VLA) systems, and robot navigation and manipulation. Recent work includes egocentric-video and robot-trajectory alignment on Unitree G1, staged egocentric-video pretraining for BAAI's EgoWorld-1, and VLA/GR00T-related mobile manipulation at LimX Dynamics. I have also led a small robotics solutions team and care about translating research into reliable applications. Reinforcement learning is not my primary specialization.
- Robotic world models and generative policies: predictive representations from video, simulation, and robot trajectories; action generation, long-horizon forecasting, and evaluation.
- VLA and real-robot systems: connecting learned representations to navigation, manipulation, and physical-robot tests.
- Multimodal memory: structured semantic-spatial retrieval for open-world object-goal navigation.
- Reproducible systems: experimental infrastructure and transparent simulation versus real-robot evidence.
- EMKG — IEEE Robotics and Automation Letters (2026), 11(4):4537–4544. DOI: 10.1109/LRA.2026.3655297.
Multimodal knowledge graph integration for open-world object-goal navigation. This project investigates the use of structured memory and multimodal retrieval to support navigation decisions.
Research focus
Visual observations are organized into semantic-spatial memory that can be queried during navigation. The work concerns the connection between environmental observations, retrieved evidence, and object-goal decisions.
World-model-assisted navigation and execution for the Go2-W platform, including map-independent charging and hybrid long-range navigation workflows.
System details and experimental materials
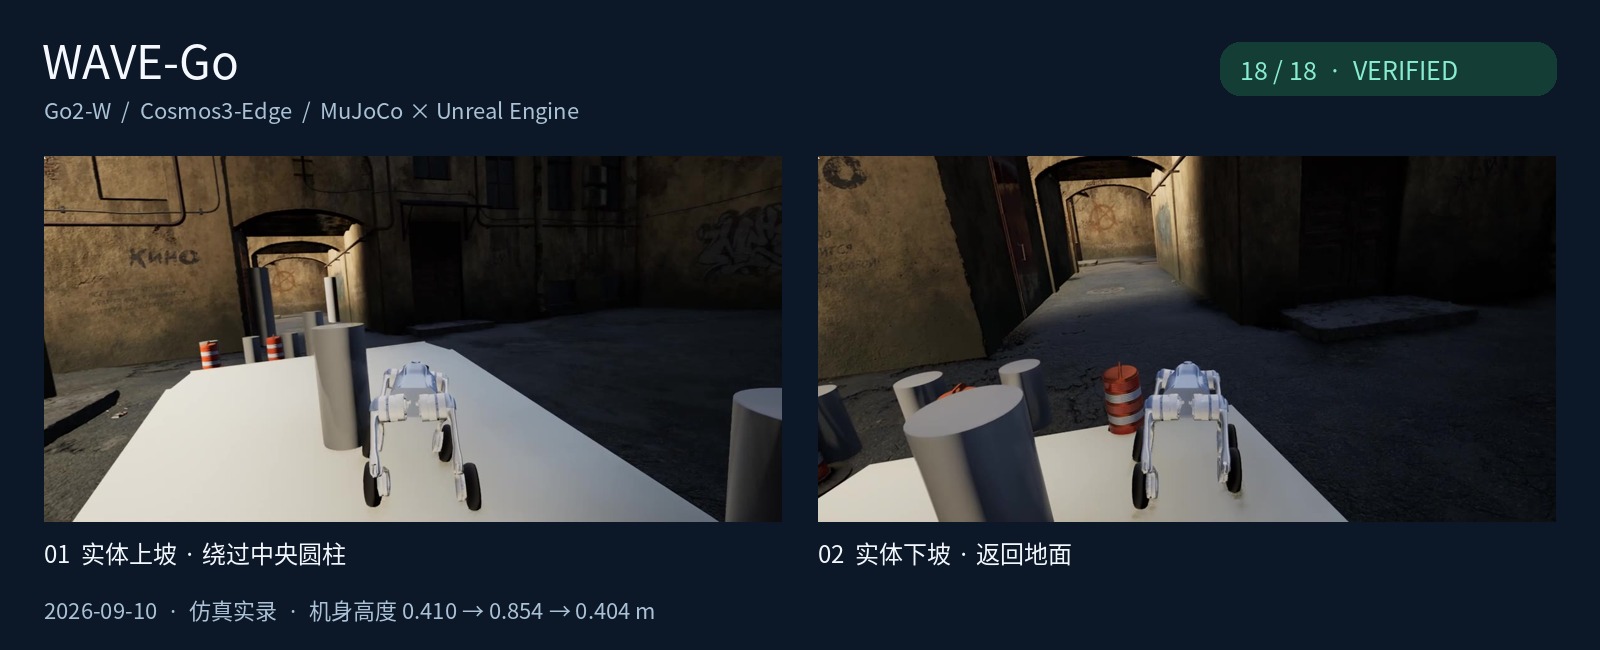
In the hybrid navigation workflow, Cosmos3-Edge selects an approved route, Nav2/RoamerX handles navigation, and DreamWaQ controls motion.
The September 10, 2026 simulation record covers stairs, ramps, and flat-ground obstacles with moving cylinder proxies. It reports 18 completed stages and 60.88 m of travel in MuJoCo / Unreal Engine, using sensor/model-fused obstacle data. These results describe the recorded simulation runs, rather than a real-robot benchmark.
An experimental framework for persona agents with explicit memory and retrieval, with adversarial smoke tests for inspecting agent behavior.
Related infrastructure
Isaac Sim Kitchen provides a reproducible Lightwheel Kitchen scene setup. Room contains related runtime work. These repositories support scripted setup, asset checks, and experimental inspection.

Current stars received across public repositories owned by this account. Automatically updated by the badge service; GitHub image caching may delay changes.